38 vex cortex diagram
When utilizing PROS in your Linux environment you cannot interact with or flash your cortex via direct A-A This is due to the fact that VEX does not provide Linux drivers for this feature that is readily... Documentation VEX Cortex Microcontroller/VEXnet Joystick User Guide VEX Robot Troubleshooting Flow Charts Cortex Microcontroller Pinout Guide Bootlader & Firmware Change Log CAD File (STEP).
For example, I want to have a Python script on a Raspberry Pi send an integer to a Vex Cortex via jump wire; is this possible?

Vex cortex diagram
Are there any 3rd party sound sensors for Vex? I know that they do not make one, but I'd like to have something controlled via a loud noise. If there is a 3rd party sound sensor, how do I use it with RobotC? This may be a nooby question but I can't find this anywhere online. How do you make functions? In javascript you can just type in "function" and then define a function, and then each time you call it the program will run that function. How can you do this in Vex? Additionally, should the function be defined in task main{}? or outside of it? Thanks in advance. The VEX Cortex Microcontroller is the next generation VEX Microcontroller. A microcontroller coordinates the flow of information and power on the robot. All other electronic system components...
Vex cortex diagram. In the debugger window it will sometimes let me adjust the power for various motors but that's just sometimes. I'm fed up and tired and I just need some help. Please? The VEX ARM® Cortex®-based Microcontroller coordinates the flow of information and power on the robot. All other electronic system components must interface to the Microcontroller. Parts Identification for VEX Robots Learn with flashcards, games and more — for free. A commonly used type of bearing in the VEX system. This bearing has three holes in a row. The VEX ARM® Cortex®-based Microcontroller coordinates the flow of all information and power on the robot. All other electronic system components (motors, sensors, etc.) interface with the...
RobotC for VEX Cortex: In this instructable, you will learn the basics of programming a VEX Cortex, in the RobotC software. Before reading this instructable, you should have a basic understanding of... EDR Cortex: VEXnet User Guide. EDR Cortex: Online Curriculum Answer Keys. How to Mount the V5 Robot Radio to the VEX EDR Clawbot. Basically discontinued (as soon as things started working). See jmesmon/hax or mkoval/hax for further development. - vex-cortex/README at master · jmesmon/vex-cortex. ROBOTC for VEX Robotics 4.x allows users to program both the VEX Cortex and the VEX IQ robotics platforms. ROBOTC users learn key skills that easily transition to the real world, industry standard...
VEX Cortex (VEX 2.0) 12 digital ports Touch Sensor, Ultrasonic Rangefinder, Shaft Encoders 8 analog inputs Light Sensors , Line Tracking Sensors, Potentiometers, Accelerometers, Gyroscope 10 motor... How to physically connect or power cycle the vex cortex to the computer. Your VEX Cortex is now ready to be programmed in ROBOTC. If you are also using the VEXnet Joysticks, you can follow the provided instructions in the VEXnet Joysticks Setup document. As promised,here's an easy to follow HOWTO for making your own VEX Cortex to NXT converter Being able to use the repository of I2C sensors available for the NXT on the Cortex unlocks many...
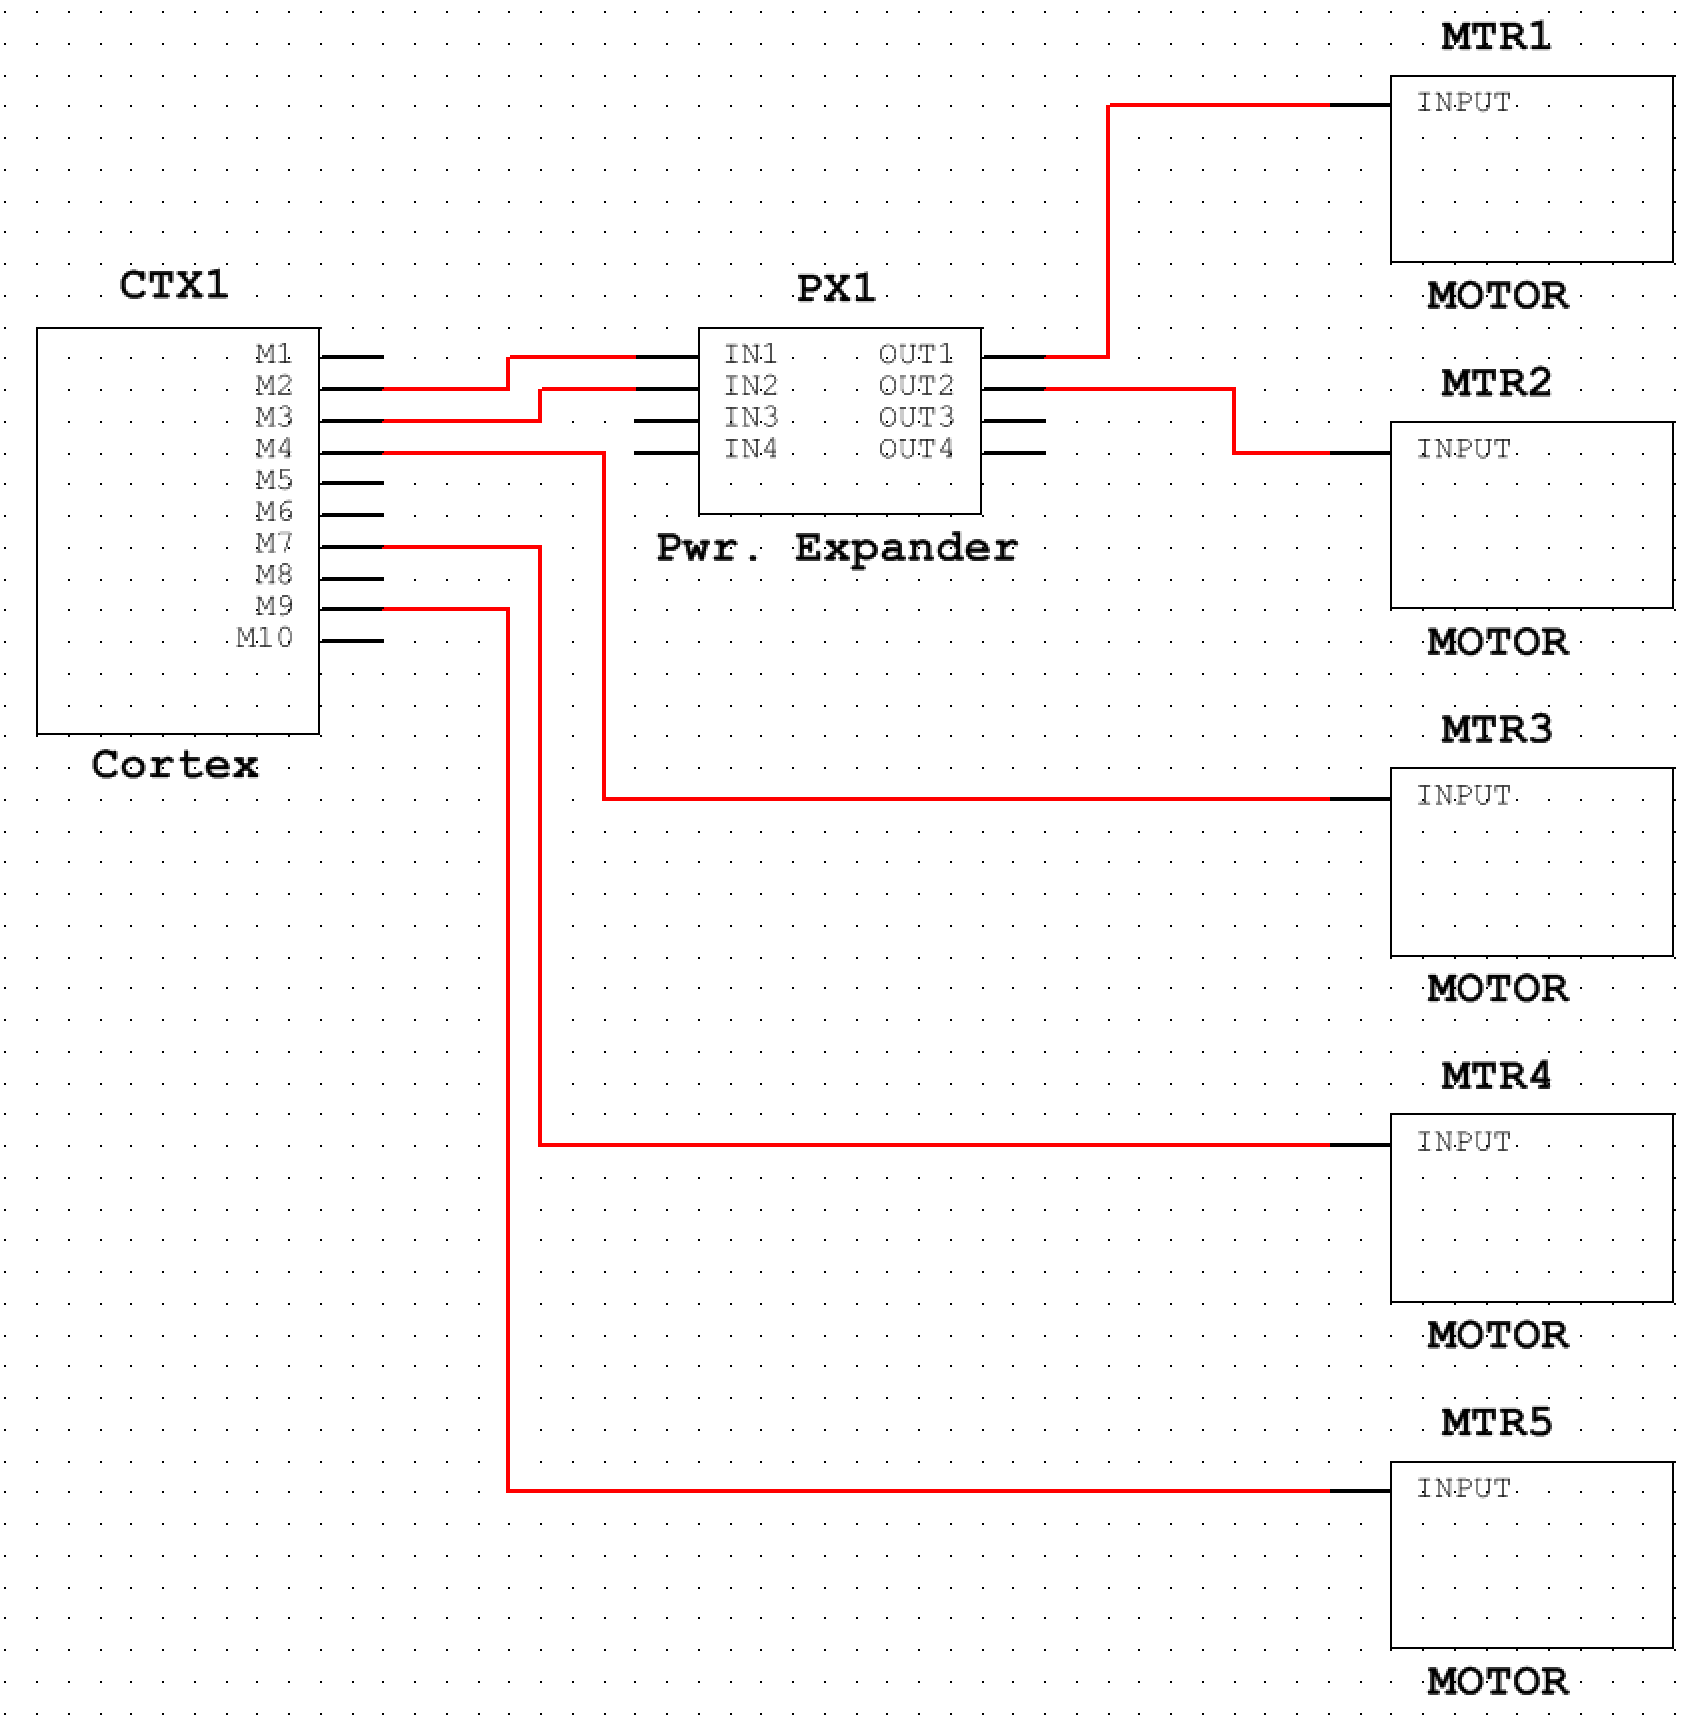
PTC Fuses in VEX Robots: A Guide - John Holbrook
We are using Vexnet 1.0 keys. Whenever we use the keys, the Cortex and Joystick do not sync. However, when we connect them using the tether USB cable, the robot is connected. We have no idea why they are not connecting. If anyone could provide any troubleshooting ideas, that would be helpful.
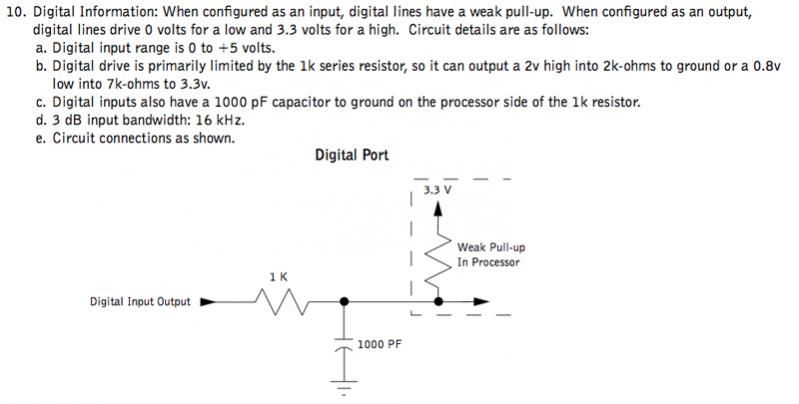
Cortex digital IO ports and the pneumatics driver - Technical ...
[First](https://www.reddit.com/r/HFY/comments/qpgysc/the_void_jockey/) [Previous](https://www.reddit.com/r/HFY/comments/ra86u9/the_void_jockey_chapter_three/) Please Note: The following has been translated from Galactic Standard to English for the benefit of its readers. Ship Log: *Peaceful Delivery* Galactic Calendar Date 3099.584 Captain Prod Galaghat. “After the ground team had been sent in, they encountered a lone alien contact inside the ship. First contact was an utter disaster. Upon...

The VEX Testbed is boring…. – Chris and Jim CIM
I have taken Comp Sci 1, so I know basic Java. I know that C is similiar to Java, but fundamentally different. http://introcs.cs.princeton.edu/java/faq/c2java.html I have been looking for the docs on RobotC, and I have found the example programs. I want to actually learn by reading the docs of RobotC, instead of skidding the example code.

Robots Thymio, VEX IQ and VEX CORTEX. | Download Scientific ...
A library of Simulink blocks for programming the VEX Cortex Microcontroller to work with servomotors, DC motors, switches, potentiometers, and VEX gamepad inputs.

Power distribution and status display for the cortex ...
© 2011 Carnegie Mellon Robotics Academy / For use with VEX Robotics Systems. ROBOTC Natural Language - VEX Cortex Reference • 1.

Robot MarketPlace - VEX Robotics Cortex Micro Controller
VEX Cortex (VEX 2.0). 12 digital ports. Touch Sensor, Ultrasonic Rangefinder, Shaft Encoders. Follow this diagram and the next several slides to configure the Test bed motors and sensors.

Power Expander: 2 Batteries Are Better than One! (Updated ...
View and Download Vex CORTEX quick start manual online. CORTEX Microcontroller and Joystick Quick Start Guide 7. 2-Wire Motor Port outputs: a. Motor Port 1 and Motor Port 10. b. Maximum motor...

How do I Handshake A VEX Cortex With a Lynxmotion Arm ...
The VEX Cortex Microcontroller coordinates the flow of all information and power on the robot. It has built in bi-directional communication for wireless driving, debugging and downloading using the state...

18 Engineering & VEX Robotics ideas | vex robotics ...
Vex engineers, is this diagram still accurate? Is there still a "Beltpack" that interfaces one Vexnet The bundle includes (1) VEX Cortex Microcontroller, (1) VEXnet Joystick, (2) VEXnet 802.11 Keys...

VEX Robotics Safety Unit CORTEX (old) by STEM Shop | TpT
Cortex Training VEX Cortex System Overview VEX Cortex Microcontroller VEX Cortex (VEX 2.0) 12 digital ports Touch Sensor, Ultrasonic Rangefinder, Shaft Encoders 8 analog…
GTT Testbed Build Instructions
The VEX Cortex Microcontroller is the next generation VEX Microcontroller. A microcontroller coordinates the flow of information and power on the robot. All other electronic system components...

19 VEX Robot Items ideas | vex robotics, robot, educational ...
This may be a nooby question but I can't find this anywhere online. How do you make functions? In javascript you can just type in "function" and then define a function, and then each time you call it the program will run that function. How can you do this in Vex? Additionally, should the function be defined in task main{}? or outside of it? Thanks in advance.
BLRS-Wiki/vex-cortex.md at master · purduesigbots/BLRS-Wiki ...
Are there any 3rd party sound sensors for Vex? I know that they do not make one, but I'd like to have something controlled via a loud noise. If there is a 3rd party sound sensor, how do I use it with RobotC?

ROBOTC for CORTEX Teacher Training - ppt download
Robotics Reference Guide

VEX Robotics Competition Logo Trademark Design, PNG ...

Understanding VEX IQ Beams and Plates – STEM Library

Getting Started with Simulink and VEX EDR V5 Video - MATLAB ...
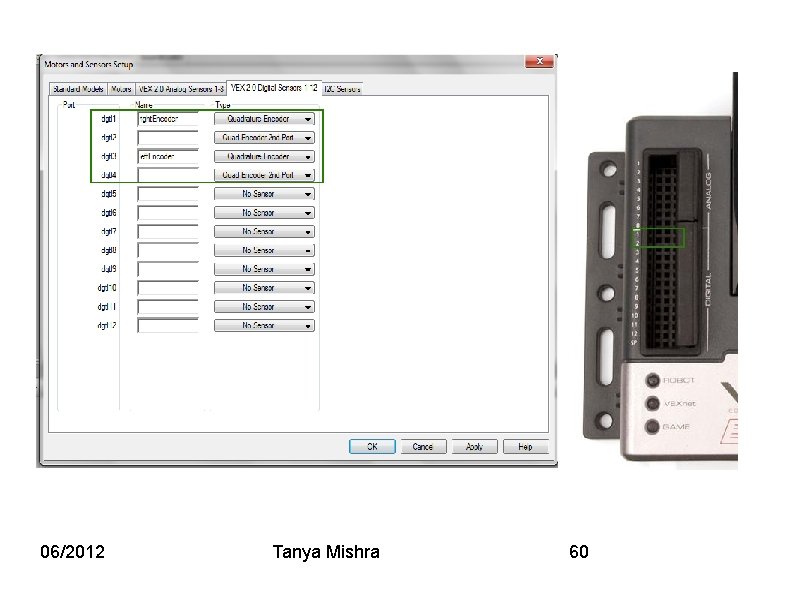
ROBOTC for VEX Cortex Llano Estacado Robo Raiders

Sketching and Drawing - VEX ROBOTICS COMPETITION

Storing and Organizing VEX IQ (1st gen) – STEM Library

VEX ROBOTICS CLAWBOT ROBOTICS ASSEMBLY MANUAL | ManualsLib

VEX | Rapid Online
VEX ARM® Cortex®-based Microcontroller and VEXnet Joystick ...
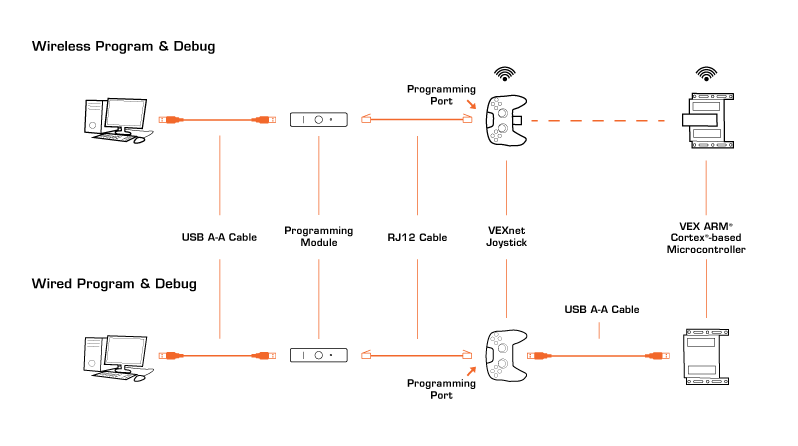
Known Issues — PROS for Cortex 2.12.2 documentation
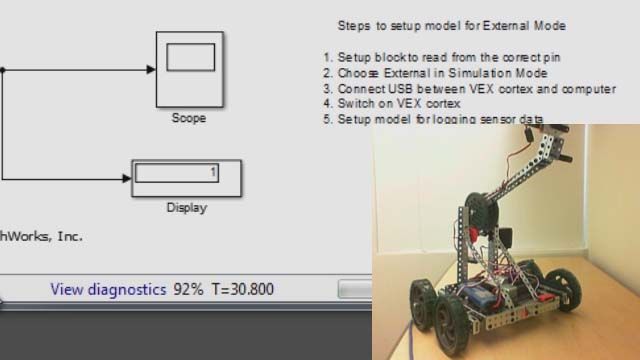
BEST Robotics Kickoff: Simulink Support for VEX Cortex ...

Vex CORTEX Programming instructions | Manualzz

Robots Thymio, VEX IQ and VEX CORTEX. | Download Scientific ...

VEX Motors Servos J M Gabrielse Motors Servos

Using the Printable VEX IQ Parts Ruler – STEM Library

Robot C and Natural Language. Create a folder Create a folder ...
CORTEX Microcontroller and Joystick Quick Start Guide

VEX ARM® Cortex®-based Microcontroller - VEX Robotics
2019-2020 Game Manual

Programming VEX Cortex Robotics with ROBOTC - ppt download
Activity 3.1.2 Basic Outputs Programming – VEX

Field control - a technical analysis - Technical Discussion ...
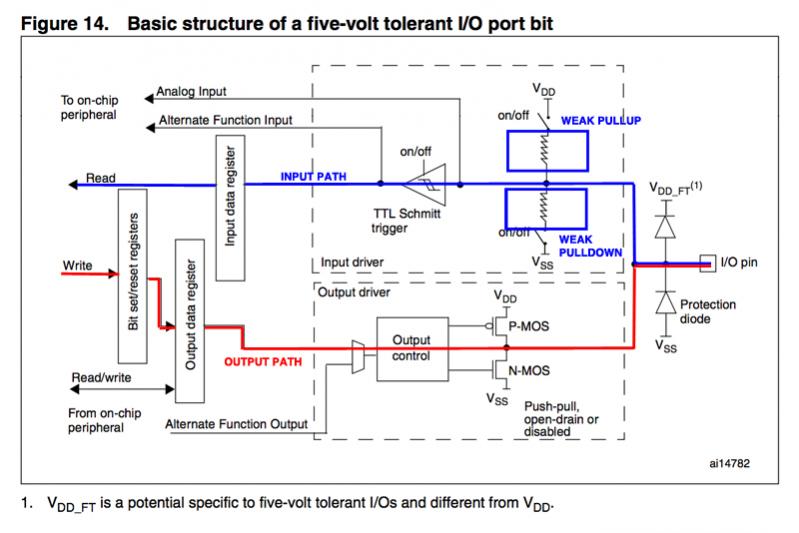
Cortex digital IO ports and the pneumatics driver - Technical ...


Comments
Post a Comment